AI Sapiens K0
ROBOTIS / KR
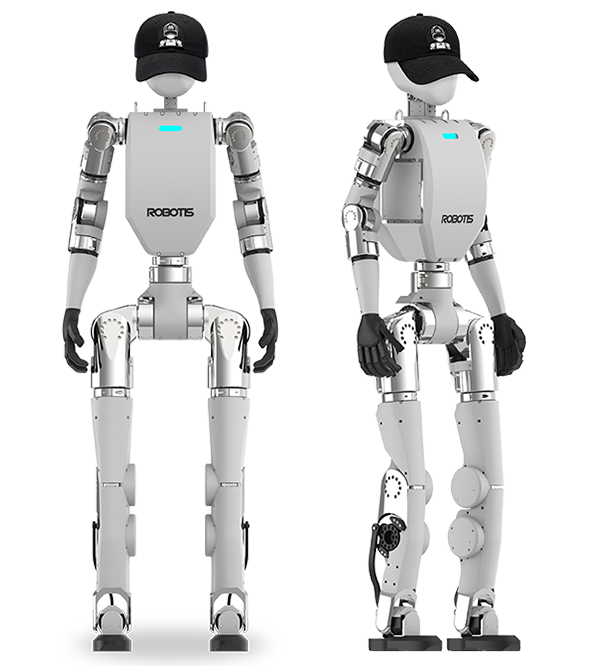
A 23-DOF biped research platform using DYNAMIXEL-Q, targeting real-hardware imitation and reinforcement learning.
- DOF
- 23
- Runtime (h)
- Unverified / undisclosed
- Peak joint torque (N·m)
- Unverified / undisclosed
- Reference price
- Unverified / undisclosed
- Learning / development
- developer
Open source & public assets
BOM, STEP, code, simulation and tutorials are described as planned staged releases. Full delivered assets and licenses are unverified; not classified as fully open.
Official figures: 1.3 m and 34 kg. Resources are described as staged releases; purchase and development-environment availability remain unverified.
Best suited for
Intended for research into locomotion control and learned policies on hardware.
Limitations
Not verified as an immediately purchasable turnkey solution. Check actual files, terms and delivery rather than treating planned releases as available.
Ownership costs
Request a complete quotation including configuration, integration and maintenance. Price and runtime remain unverified.
Support & repair
AI Worker is listed in the official Japan shop with price and delivery by inquiry. Confirm domestic repair scope, fees and spare-parts availability before ordering.
Additional sources
ai.robotis.com ↗robotis.com ↗Source checked:
Editorial source review: ROBO COMPASS. Manufacturer claims are not independent test results.
Official specifications ↗