ROBO COMPASS / REFERENCE
Berkeley Humanoid Lite
UC Berkeley / Hybrid Robotics / US
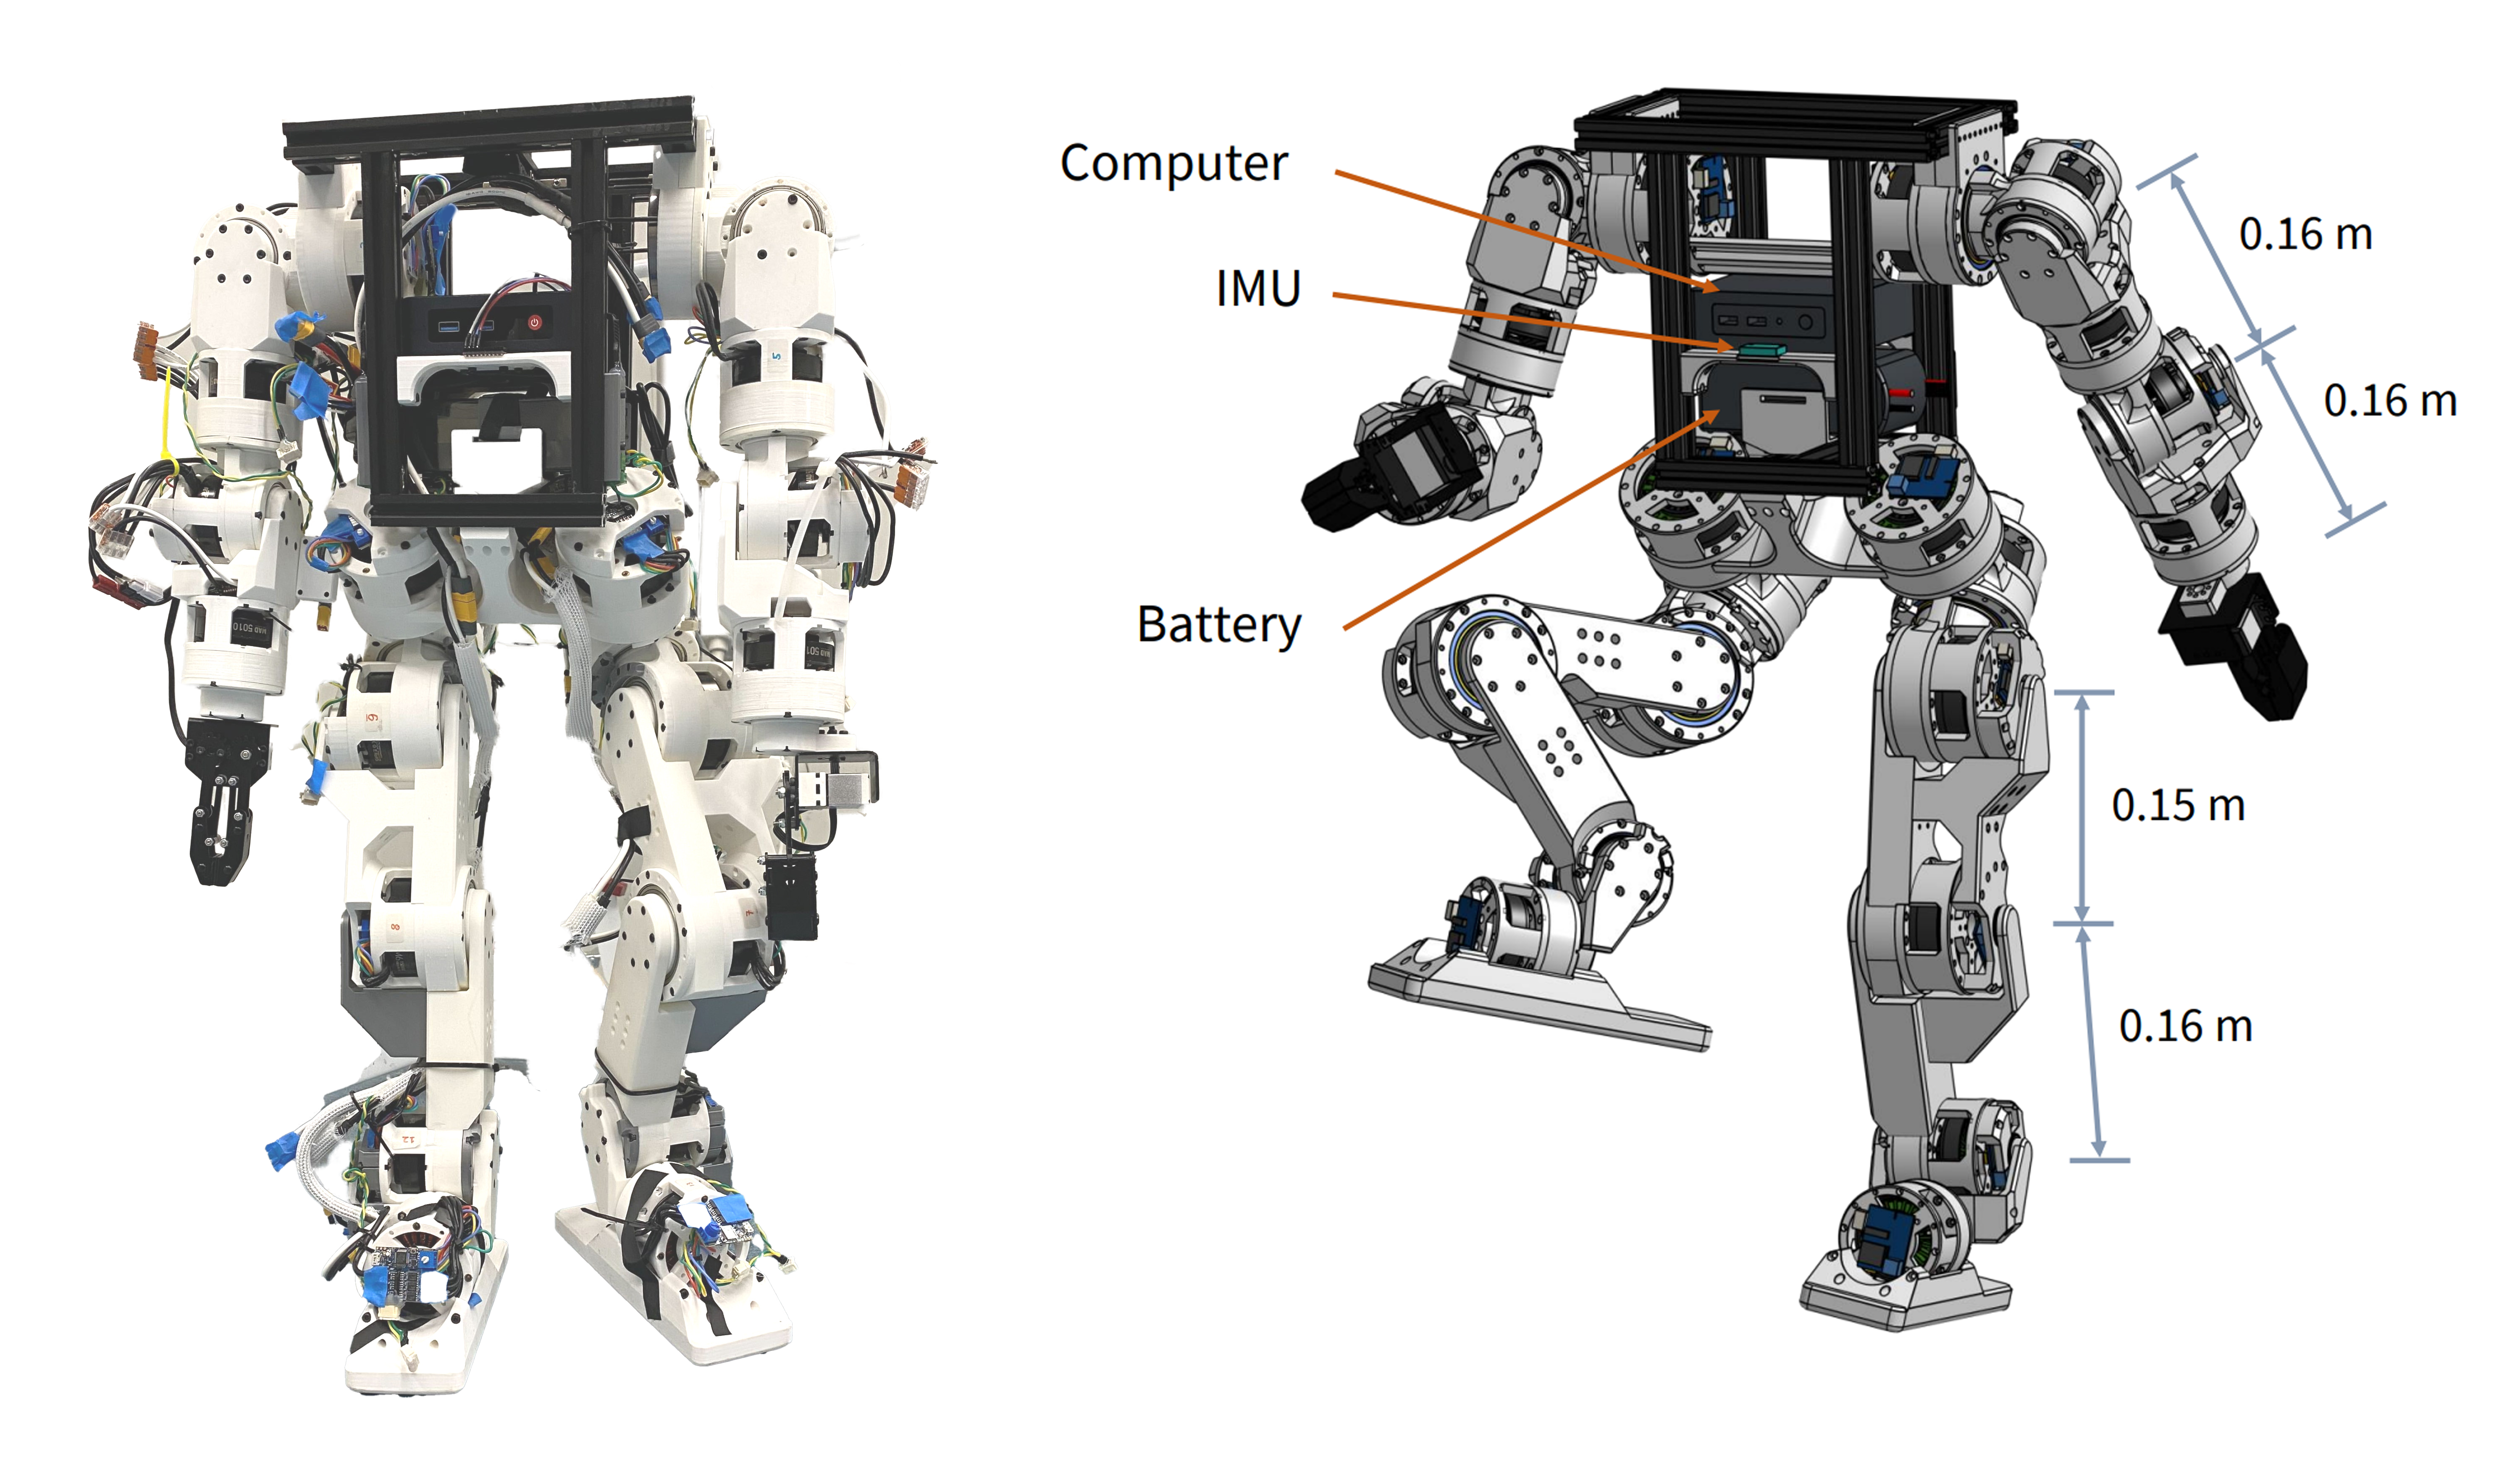
A buildable research humanoid using 3D-printed gearboxes and off-the-shelf components.
- DOF
- Unverified / undisclosed
- Runtime (h)
- Unverified / undisclosed
- Peak joint torque (N·m)
- Unverified / undisclosed
- Reference price
- Unverified / undisclosed
- Learning / development
- developer
Open source & public assets
Code, design assets and build documentation for a self-sourced, 3D-printed build.
GitHub ↗Code: MIT ↗Other assets: CC BY-SA 4.0 ↗Sub-USD 5,000 is a US-market hardware build-cost claim, not a finished-robot retail price.
Source checked:
Editorial source review: ROBO COMPASS. Manufacturer claims are not independent test results.
Official specifications ↗