ROBO COMPASS / REFERENCE
TALOS
PAL Robotics / ES
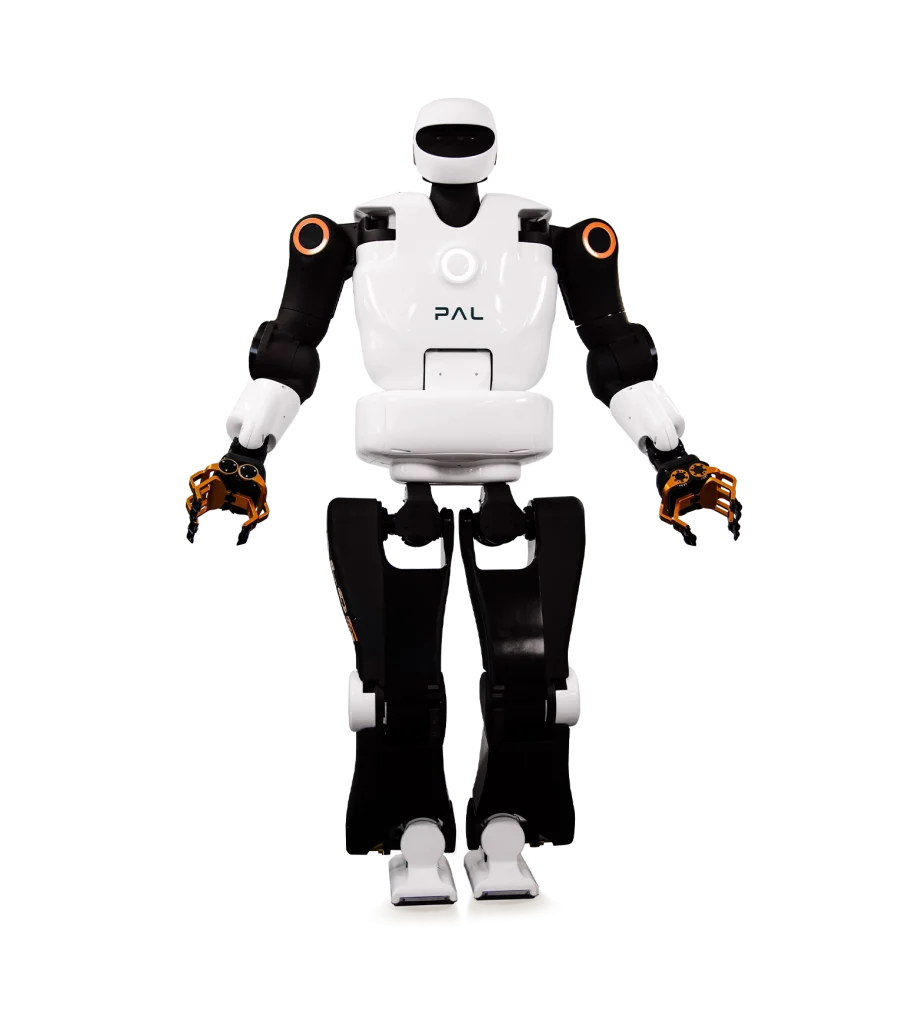
A ROS-based biped research platform with torque-sensor-based whole-body control.
- DOF
- Unverified / undisclosed
- Runtime (h)
- 1.5
- Peak joint torque (N·m)
- Unverified / undisclosed
- Reference price
- Unverified / undisclosed
- Learning / development
- developer
1.5 hours walking, 3 hours standby. Some joints excluded from torque sensing.
Source checked:
Editorial source review: ROBO COMPASS. Manufacturer claims are not independent test results.
Official specifications ↗