ROBO COMPASS / REFERENCE
RP1 / ROBOTO 01
RoboParty / CN
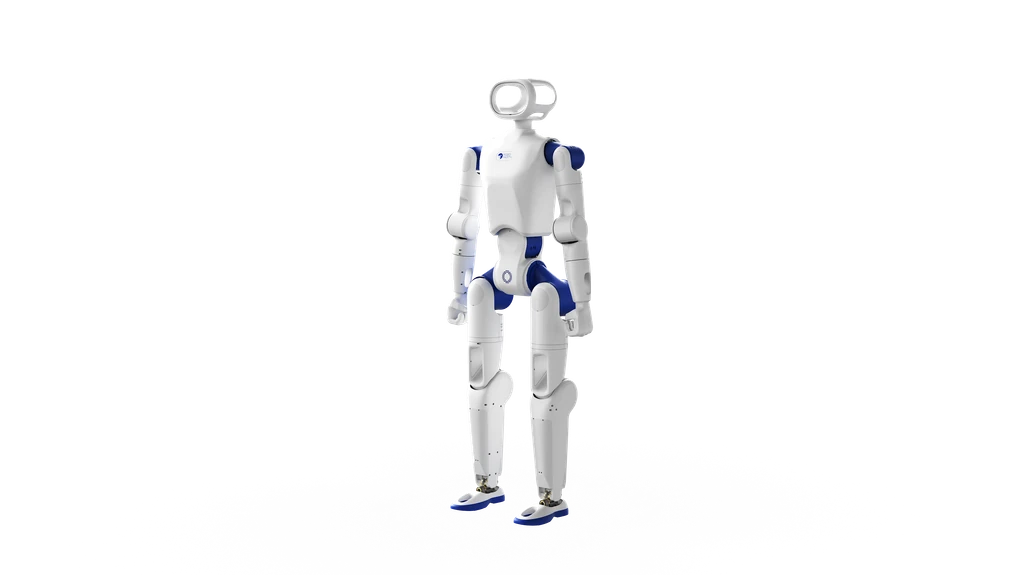
A developer platform exposing hardware, electronics, control and learning.
- DOF
- 24
- Runtime (h)
- 3
- Peak joint torque (N·m)
- 160
- Reference price
- Unverified / undisclosed
- Learning / development
- developer
Open source & public assets
CAD, circuits, PCB, BOM, assembly, control and learning. Check each sub-repository for releases and licenses.
GitHub ↗Overview repository: GPL-3.0 ↗24-DoF product-page configuration. 160 N·m is the peak for the 100 mm module, not every joint. Repository variants (24/28/30/42 DoF) are separate.
Source checked:
Editorial source review: ROBO COMPASS. Manufacturer claims are not independent test results.
Official specifications ↗