ROBO COMPASS / REFERENCE
PM01 EDU
EngineAI / CN
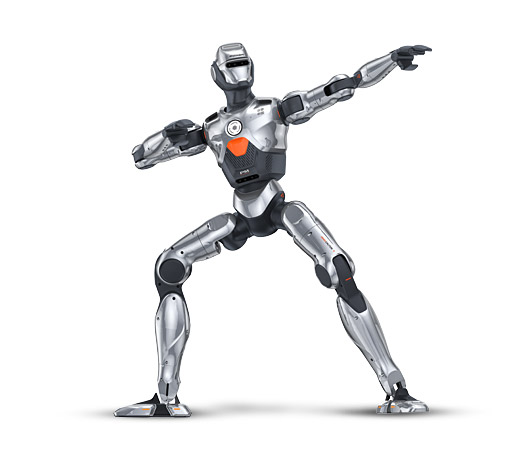
A compact humanoid for research, education and industrial development.
- DOF
- 24
- Runtime (h)
- 2
- Peak joint torque (N·m)
- 145
- Reference price
- Unverified / undisclosed
- Learning / development
- developer
Based on PM01 EDU developer docs. 145 N·m is joint torque; do not confuse with 130 N·m/kg torque density on the homepage.
Source checked:
Editorial source review: ROBO COMPASS. Manufacturer claims are not independent test results.
Official specifications ↗